Schmalz CobotPump | Elektrische vacuümpomp voor cobots | groot

Varianten: Fairino FR3-30
De CobotPump-modellen zijn ontwikkeld voor efficiënte materiaalverwerking met robotsystemen. Hun robuuste elektrische vacuümtechnologie onderscheidt zich door betrouwbaarheid, flexibiliteit en een compact ontwerp. Dankzij de krachtige constructie garandeert de CobotPump een nauwkeurige regeling en snelle reactietijden – ideaal voor veeleisende automatiseringstoepassingen.
De integratie in bestaande automatiseringssystemen is bijzonder eenvoudig dankzij beproefde digitale interfaces zoals de M12-8-polige stekkerverbinding. Een NFC-interface vergemakkelijkt de comfortabele parametrering en gegevensoverdracht via smartphone. De intuïtieve software en plug-and-play-functionaliteit minimaliseren de installatietijd en garanderen een snelle inzetbaarheid.
Optimaal voor nauwkeurige materiaalverwerking, logistiek en productietoepassingen – de CobotPump biedt efficiëntie, veelzijdigheid en gebruiksvriendelijkheid.
Hoogtepunten
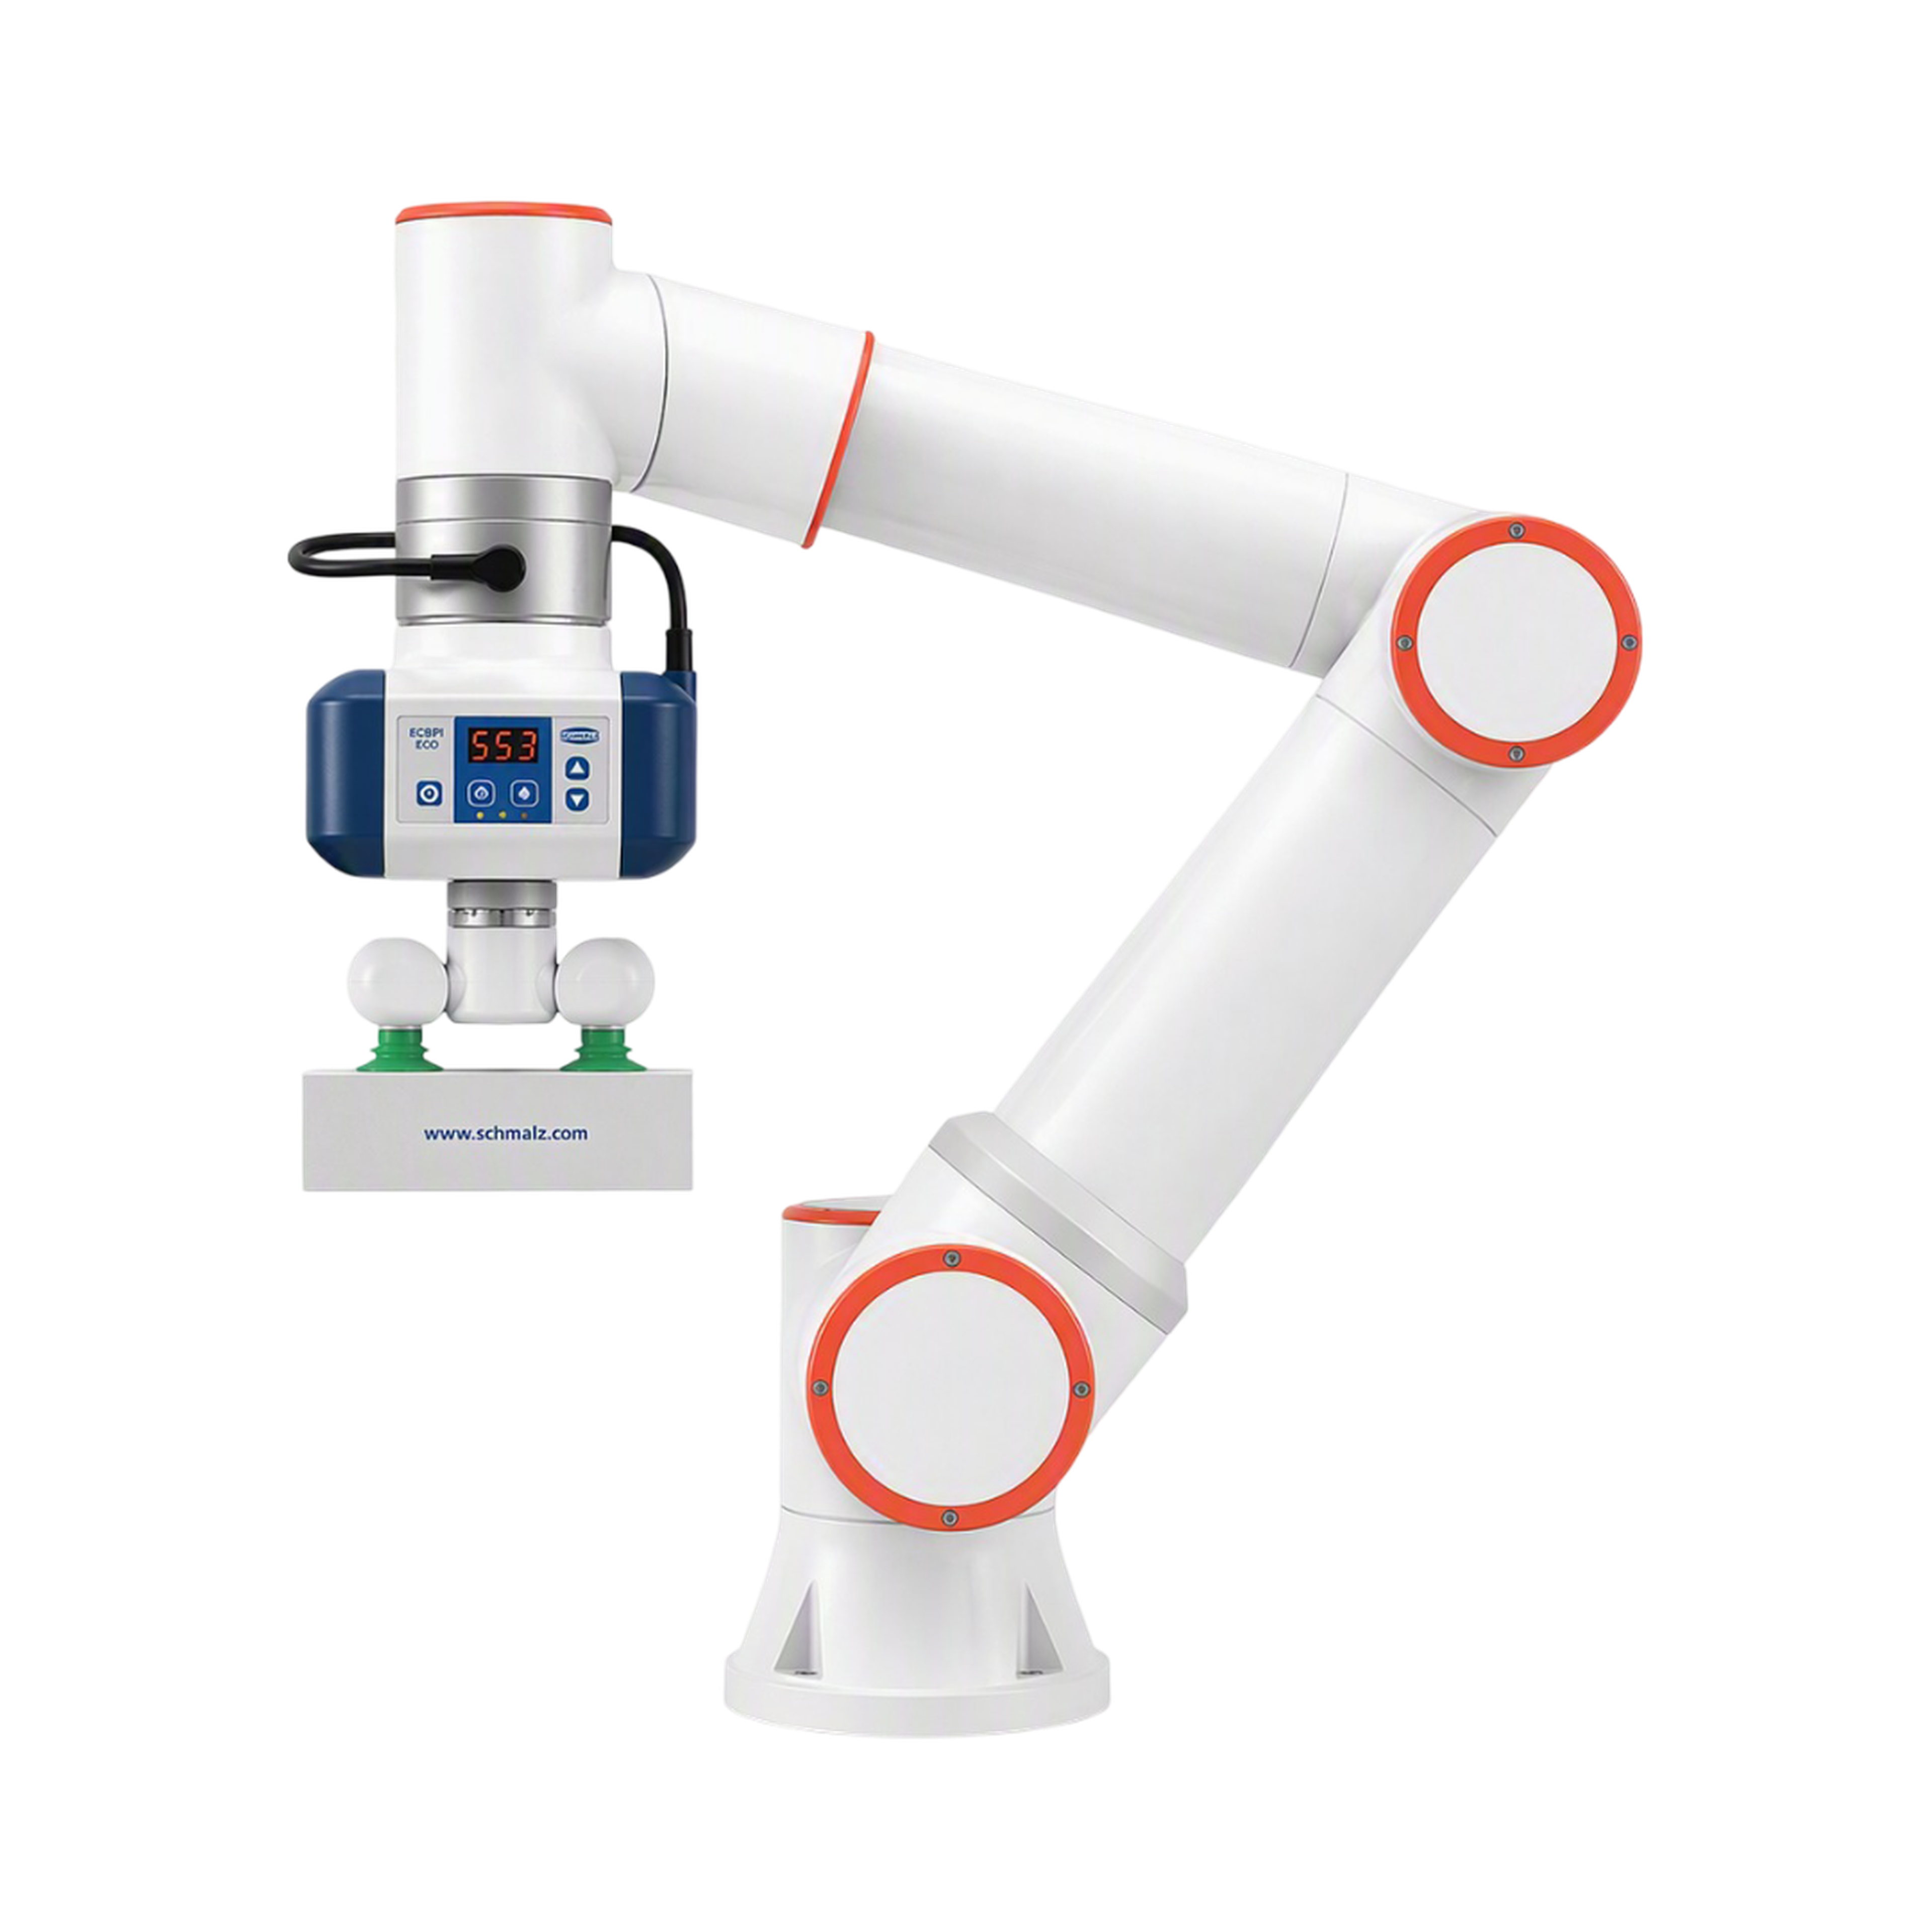
A comprehensive solution for rapid FAIRINO integration
With the ECBPi FAIRINO from Schmalz, users receive a fully coordinated robotics kit for connecting and integrating the CobotPump ECBPi with FAIRINO lightweight robots. The kit significantly simplifies the implementation of automation projects, as all the components required for mechanical and functional integration are optimally coordinated. This significantly reduces the effort involved in planning, procurement and installation. The compact design is suitable for use with FAIRINO robots from the FR3, FR5 and FR10 series and provides the ideal basis for efficient handling, pick-and-place and logistics processes. This enables companies to move more quickly from the initial project idea to a productive robotic application.
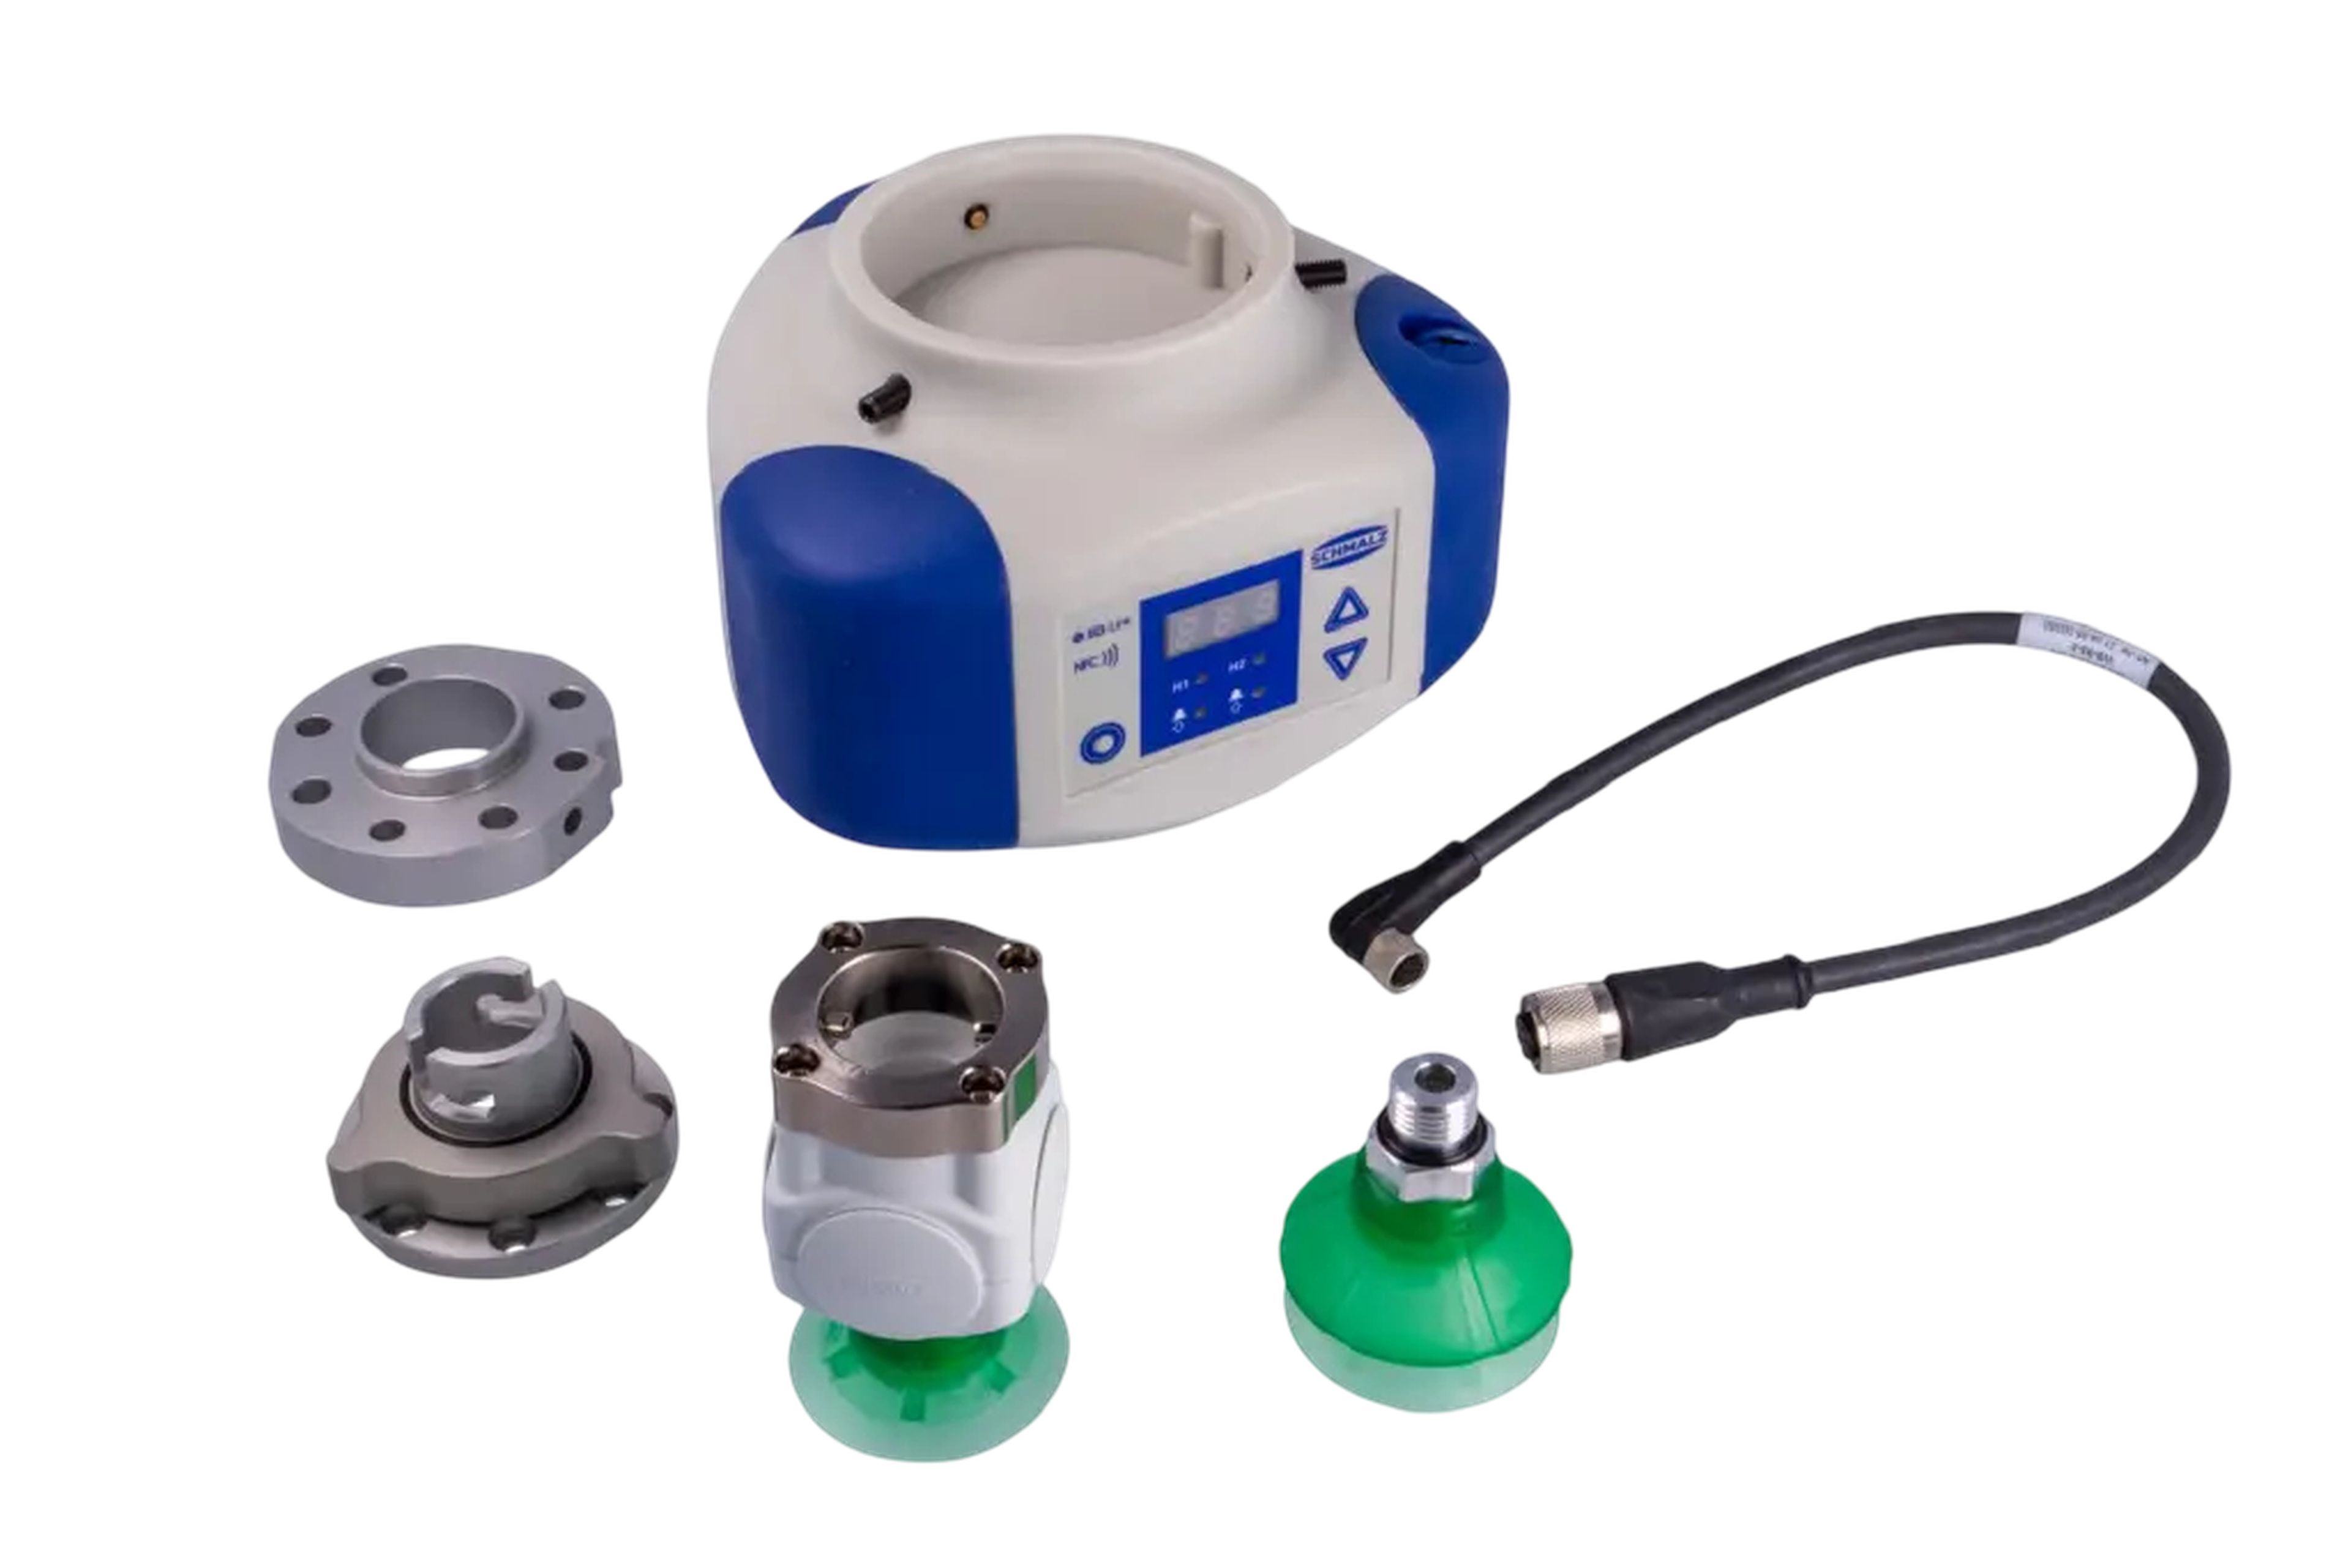
Flexible vacuum automation for dynamic processes
The ECBPi FAIRINO combines the electric vacuum technology of the CobotPump ECBPi with a modular end-of-arm concept for maximum application flexibility. Different workpieces and varying requirements can be handled efficiently using compatible vacuum end-effectors and accessory solutions, without the need to redesign the entire gripper structure. The vacuum generation system, integrated directly onto the robot, reduces the need for external infrastructure and supports a lean cell design. At the same time, the compact arrangement of the components ensures low loads on the robot joint and enables dynamic movement sequences. This makes the system the ideal choice for companies seeking to implement flexible automation solutions with high process reliability and rapid adaptability.
Goedkope oplossingen gebouwd met RBTX
Boek een gratis videogesprek met onze experts


